02.14 · Student project
Rotary inverted pendulum
Students built a mechanical structure with a servo motor and successfully stabilised the pendulum in the upright position.
About the project
The aim was to build a mechanical structure and stabilise the pendulum in the upright position. A servo motor fitted in the structure moves the arm and with it the pendulum. The system is controlled by a programmable logic controller (PLC) and the motor by a servo drive; communication uses the CC-Link industrial Ethernet standard.
The arm angle is sensed by an incremental encoder coupled to the motor, and the pendulum angle by an additional incremental encoder. An HMI screen is used for operation and data display.
How it works
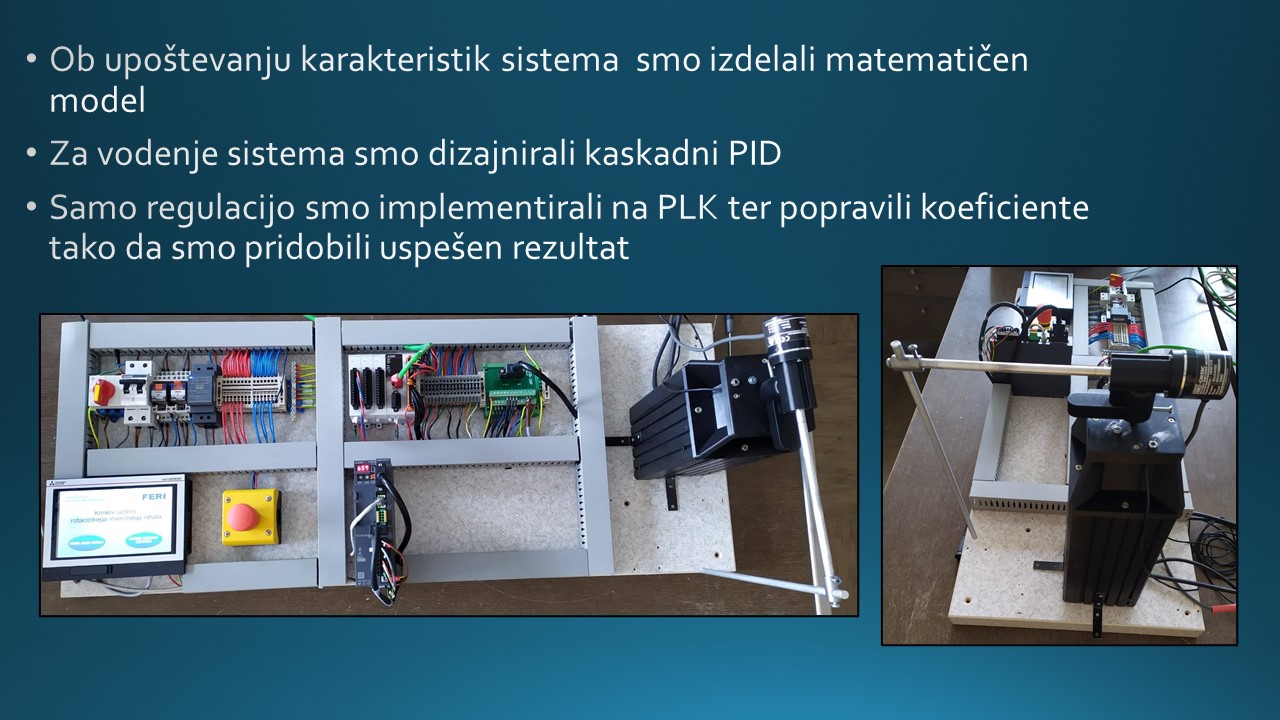
- Model: taking the system's characteristics into account, we built a mathematical model.
- Controller: we designed a cascade PID controller to control the system.
- Implementation: we implemented the control on the PLC and tuned the coefficients so that the pendulum stands upright.
| Type | Student project |
| Controller | Mitsubishi FX5UC-32MT/DSS-TS PLC |
| Drive | Mitsubishi HG-KN13J servo motor, MR-JE-10C servo drive |
| Sensors | Two incremental encoders (arm angle, pendulum angle) |
| Communication | CC-Link |
| HMI | Mitsubishi GT2107-WTSD |
| Controller | Cascade PID |

Presentation