01.11 · Master's thesis
Localisation with ultra-wideband radio
The position of a node is determined from the time of flight of ultra-wideband (UWB) radio signals to fixed anchor points – even indoors, where GPS does not work.
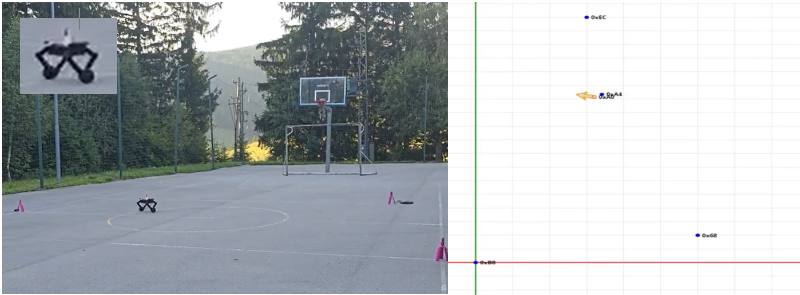
Illustration · distances to anchors → position estimate with WLS
About the project
The position of a node is determined from the time of flight of ultra-wideband (UWB) radio signals to fixed anchor points – even indoors, where GPS does not work.
Ultra-wideband radio transmits very short pulses, so the receiver can determine their time of arrival very precisely. From the signal's time of flight we get the distance to each anchor. With the distances to several anchors, the robot's position is found as the intersection of circles around the anchors.
How it works
- The anchors are placed at known, fixed positions around the driving area.
- Distance measurement: the node on the robot uses UWB pulses to measure the time of flight to each anchor and converts it into a distance.
- WLS (weighted least squares) computes from all the distances the position that best fits the measurements; more reliable measurements get a larger weight.
- Filtering: the video also shows calibration and the EKF and UKF filters, which smooth the sequence of estimates while driving.
| Type | Master's thesis |
| Field | Remote control · Navigation |
| Technology | Ultra-wideband radio (UWB) |
| Measurement | Time of flight of the signal to the anchor points |
| Position estimate | WLS, EKF and UKF filters |